Infra Infrastructure
Hardware and software resources for VL4AI members.
DJI Matrice 300 RTK 'FENYX'
An industrial multi-rotor platform featuring centimetre-level RTK accuracy, multi-directional dual-vision sensing, and swappable payload mounts. Designed for all-weather stability and extended outdoor flight.
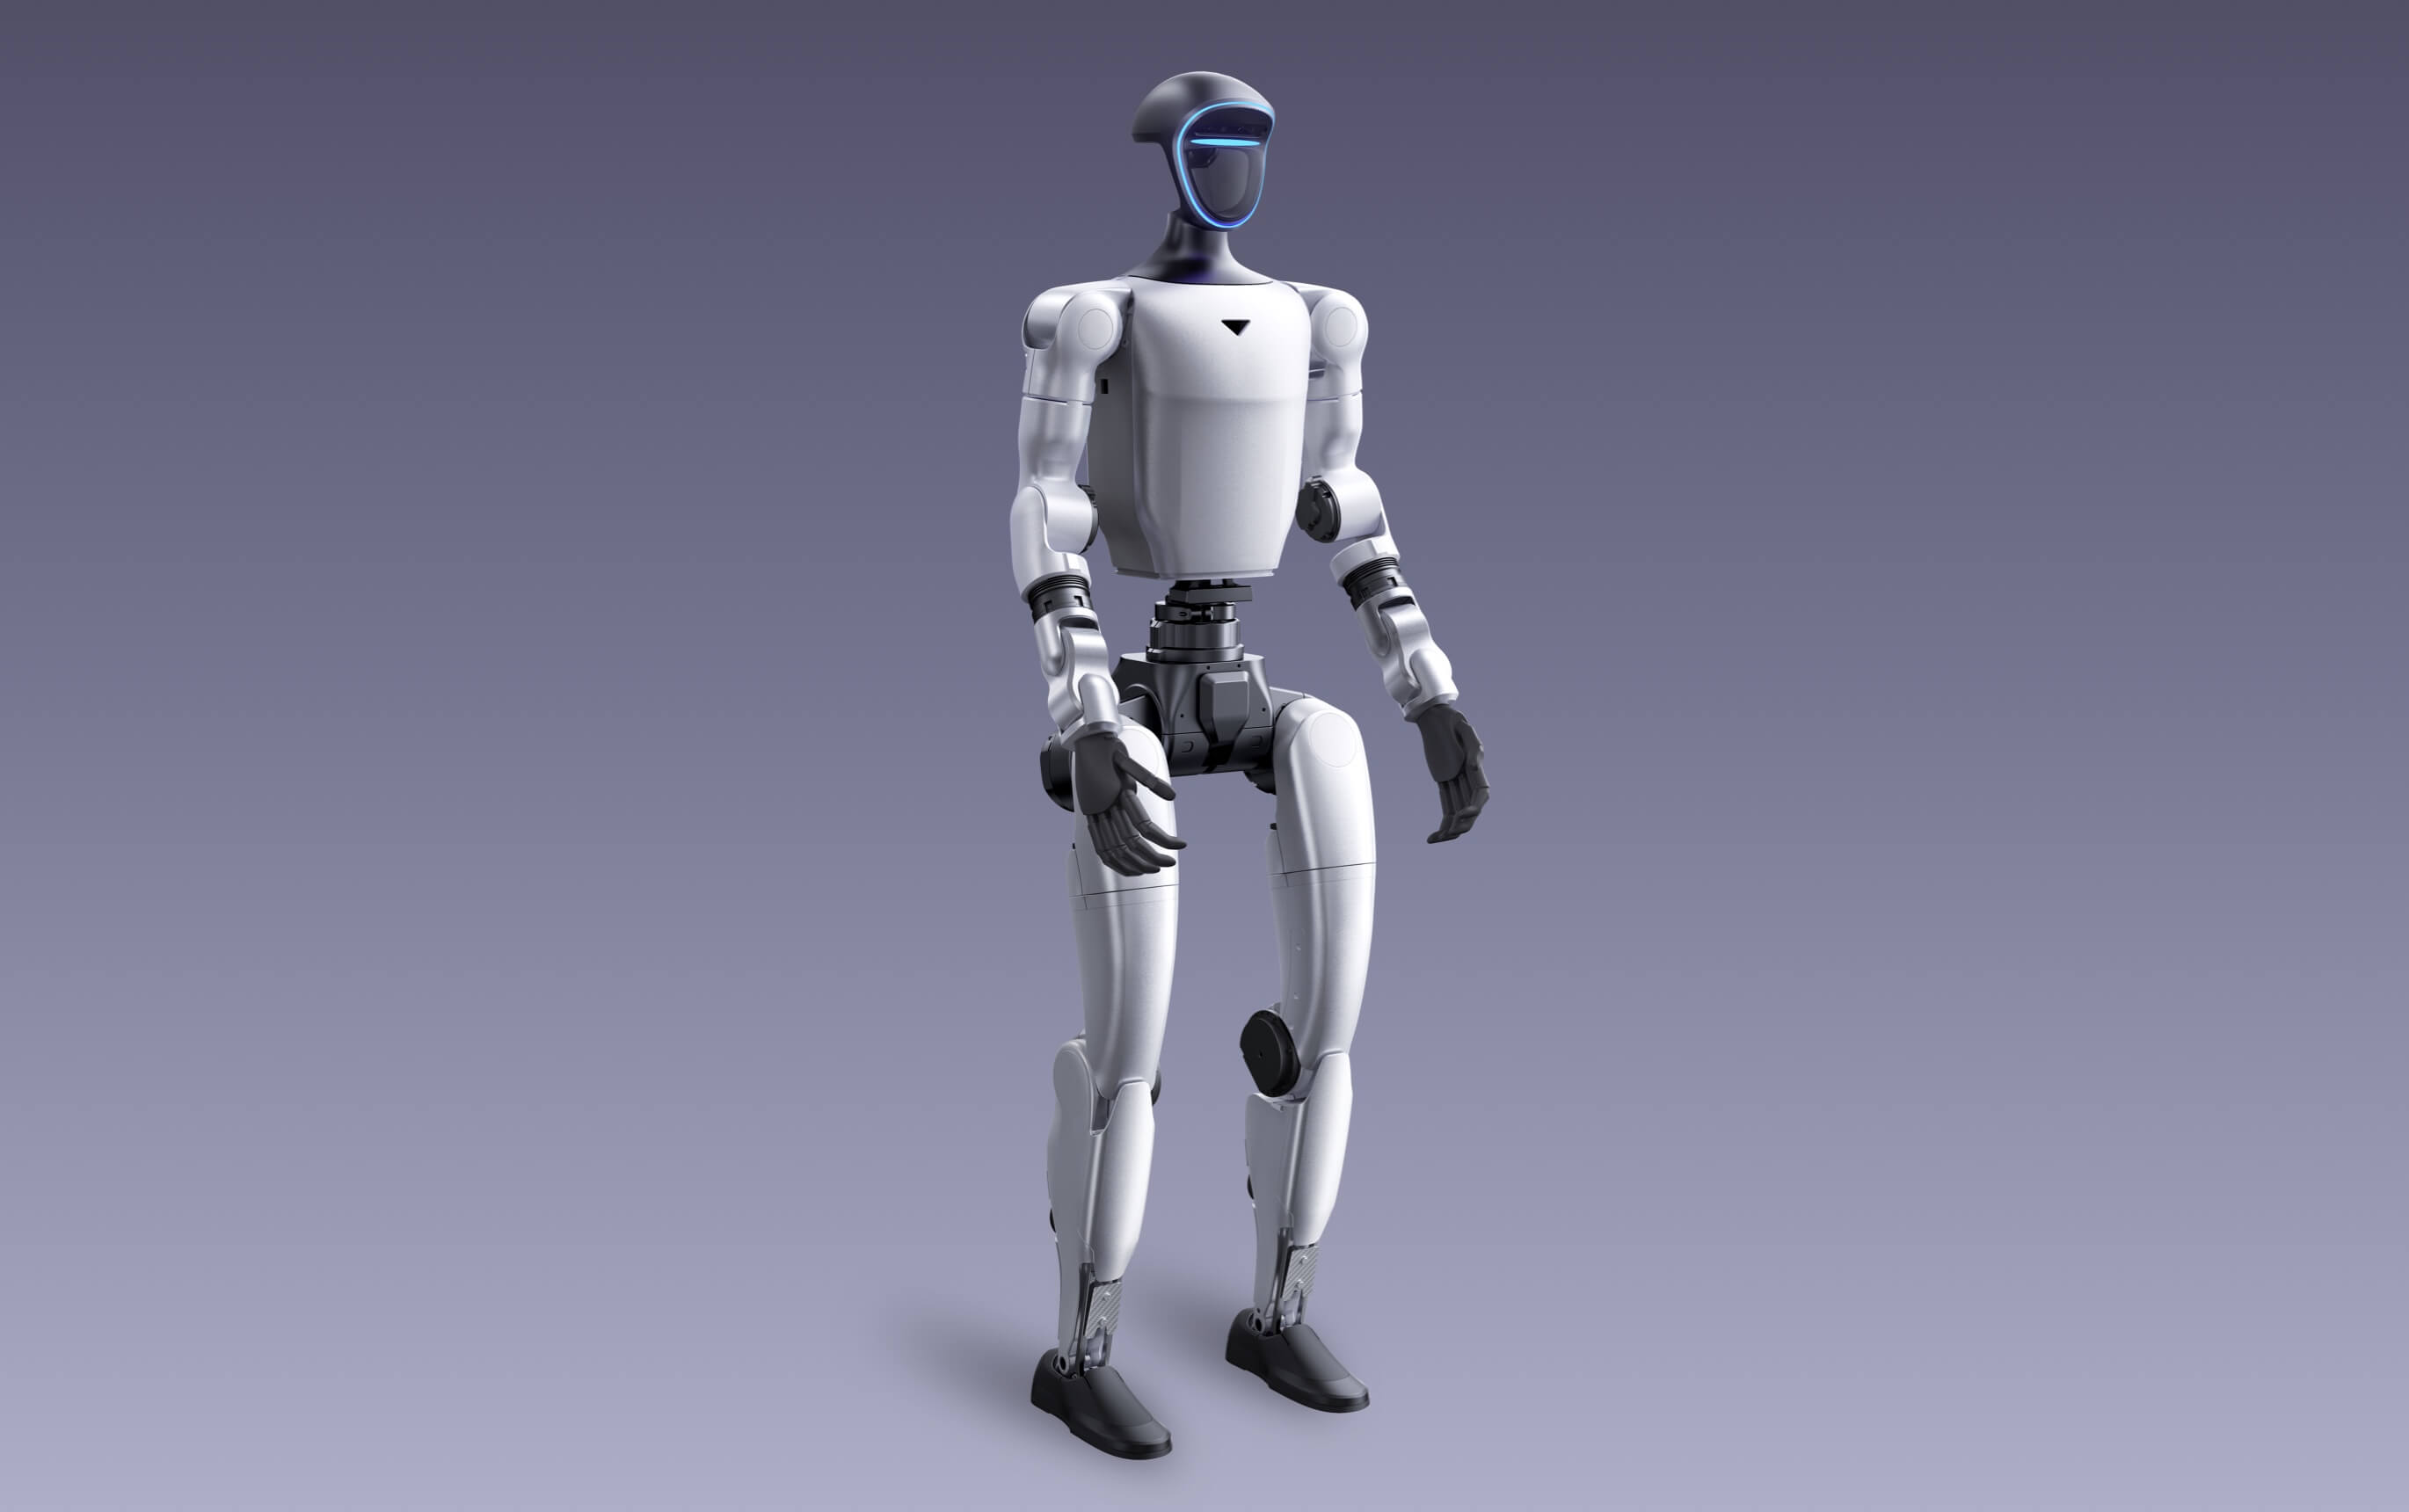
Unitree G1 Humanoid Robot 'IRIS'
A compact bipedal humanoid platform featuring 3D LiDAR perception and high-torque joint actuators. Built for dynamic locomotion and dexterous manipulation.
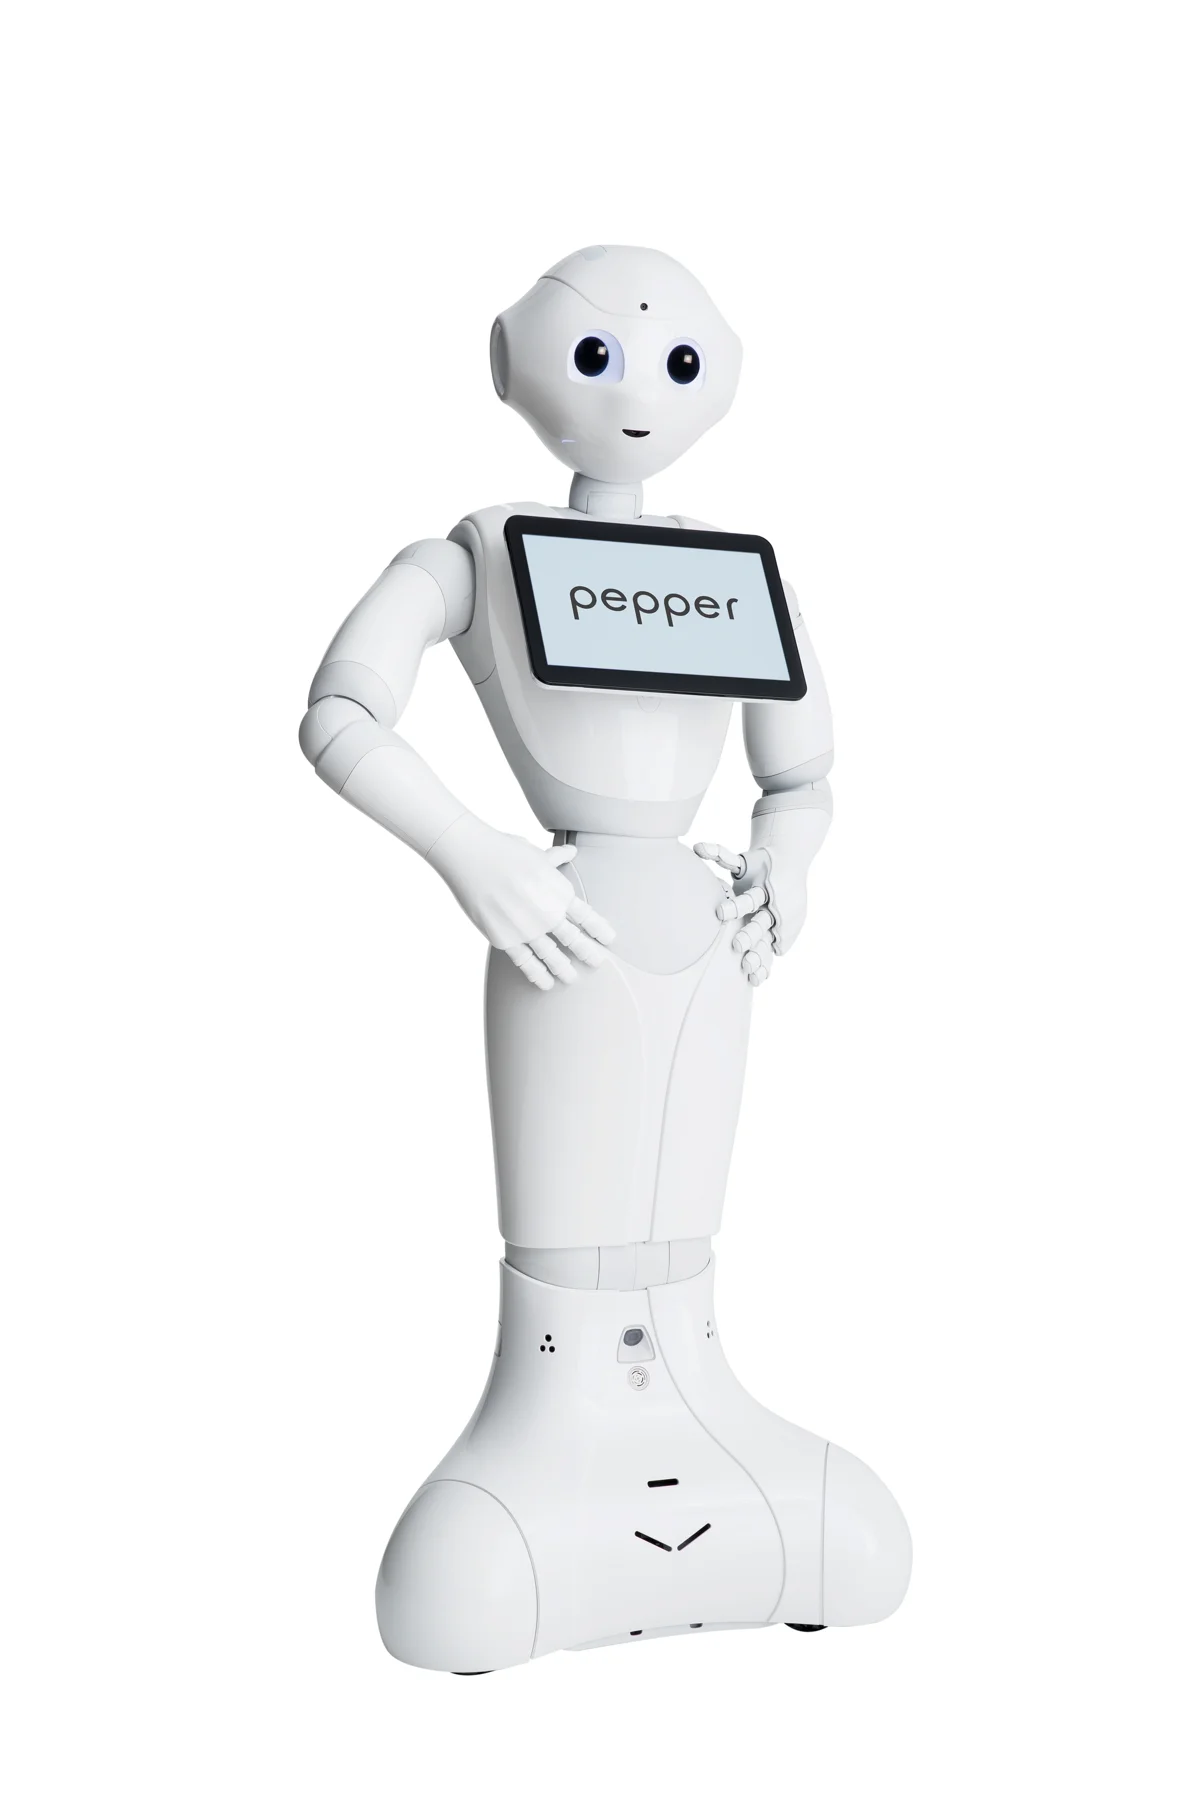
SoftBank Pepper Robot 'GINNY'
A humanoid platform for human-robot interaction work: speech, gaze, gesture, and a tablet as the shared surface between person and robot.
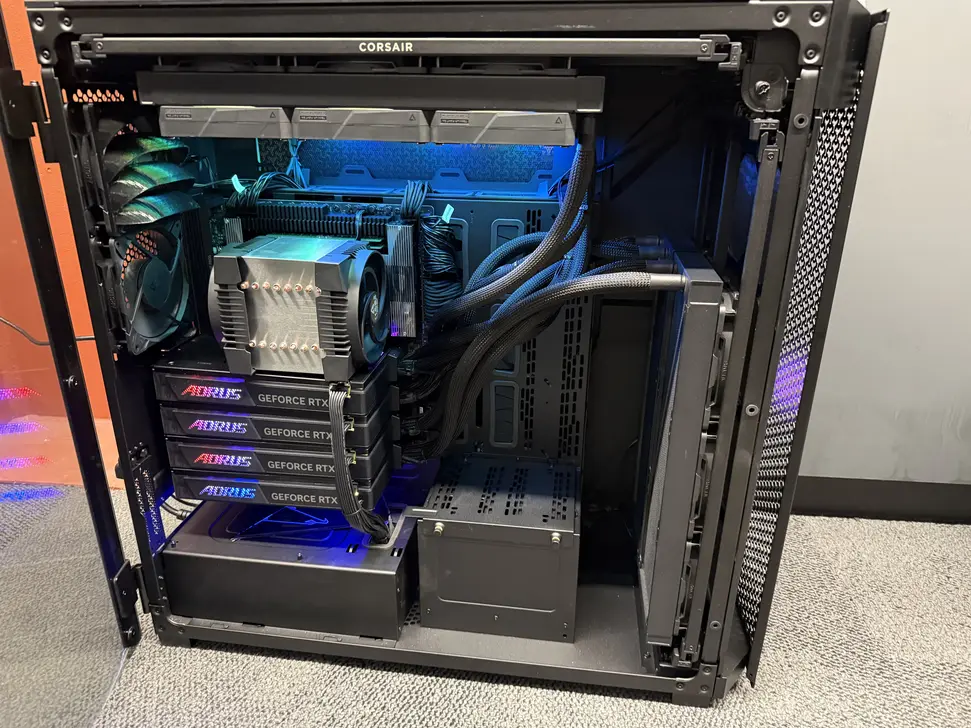
GPU workstations
Physical workstations in the lab, open to every member: around 30 GPUs across RTX 4090, RTX 5090, and L40s. Machines you sit at rather than queue for, for dataset work, robotics development, debugging, and training runs that do not need a cluster.
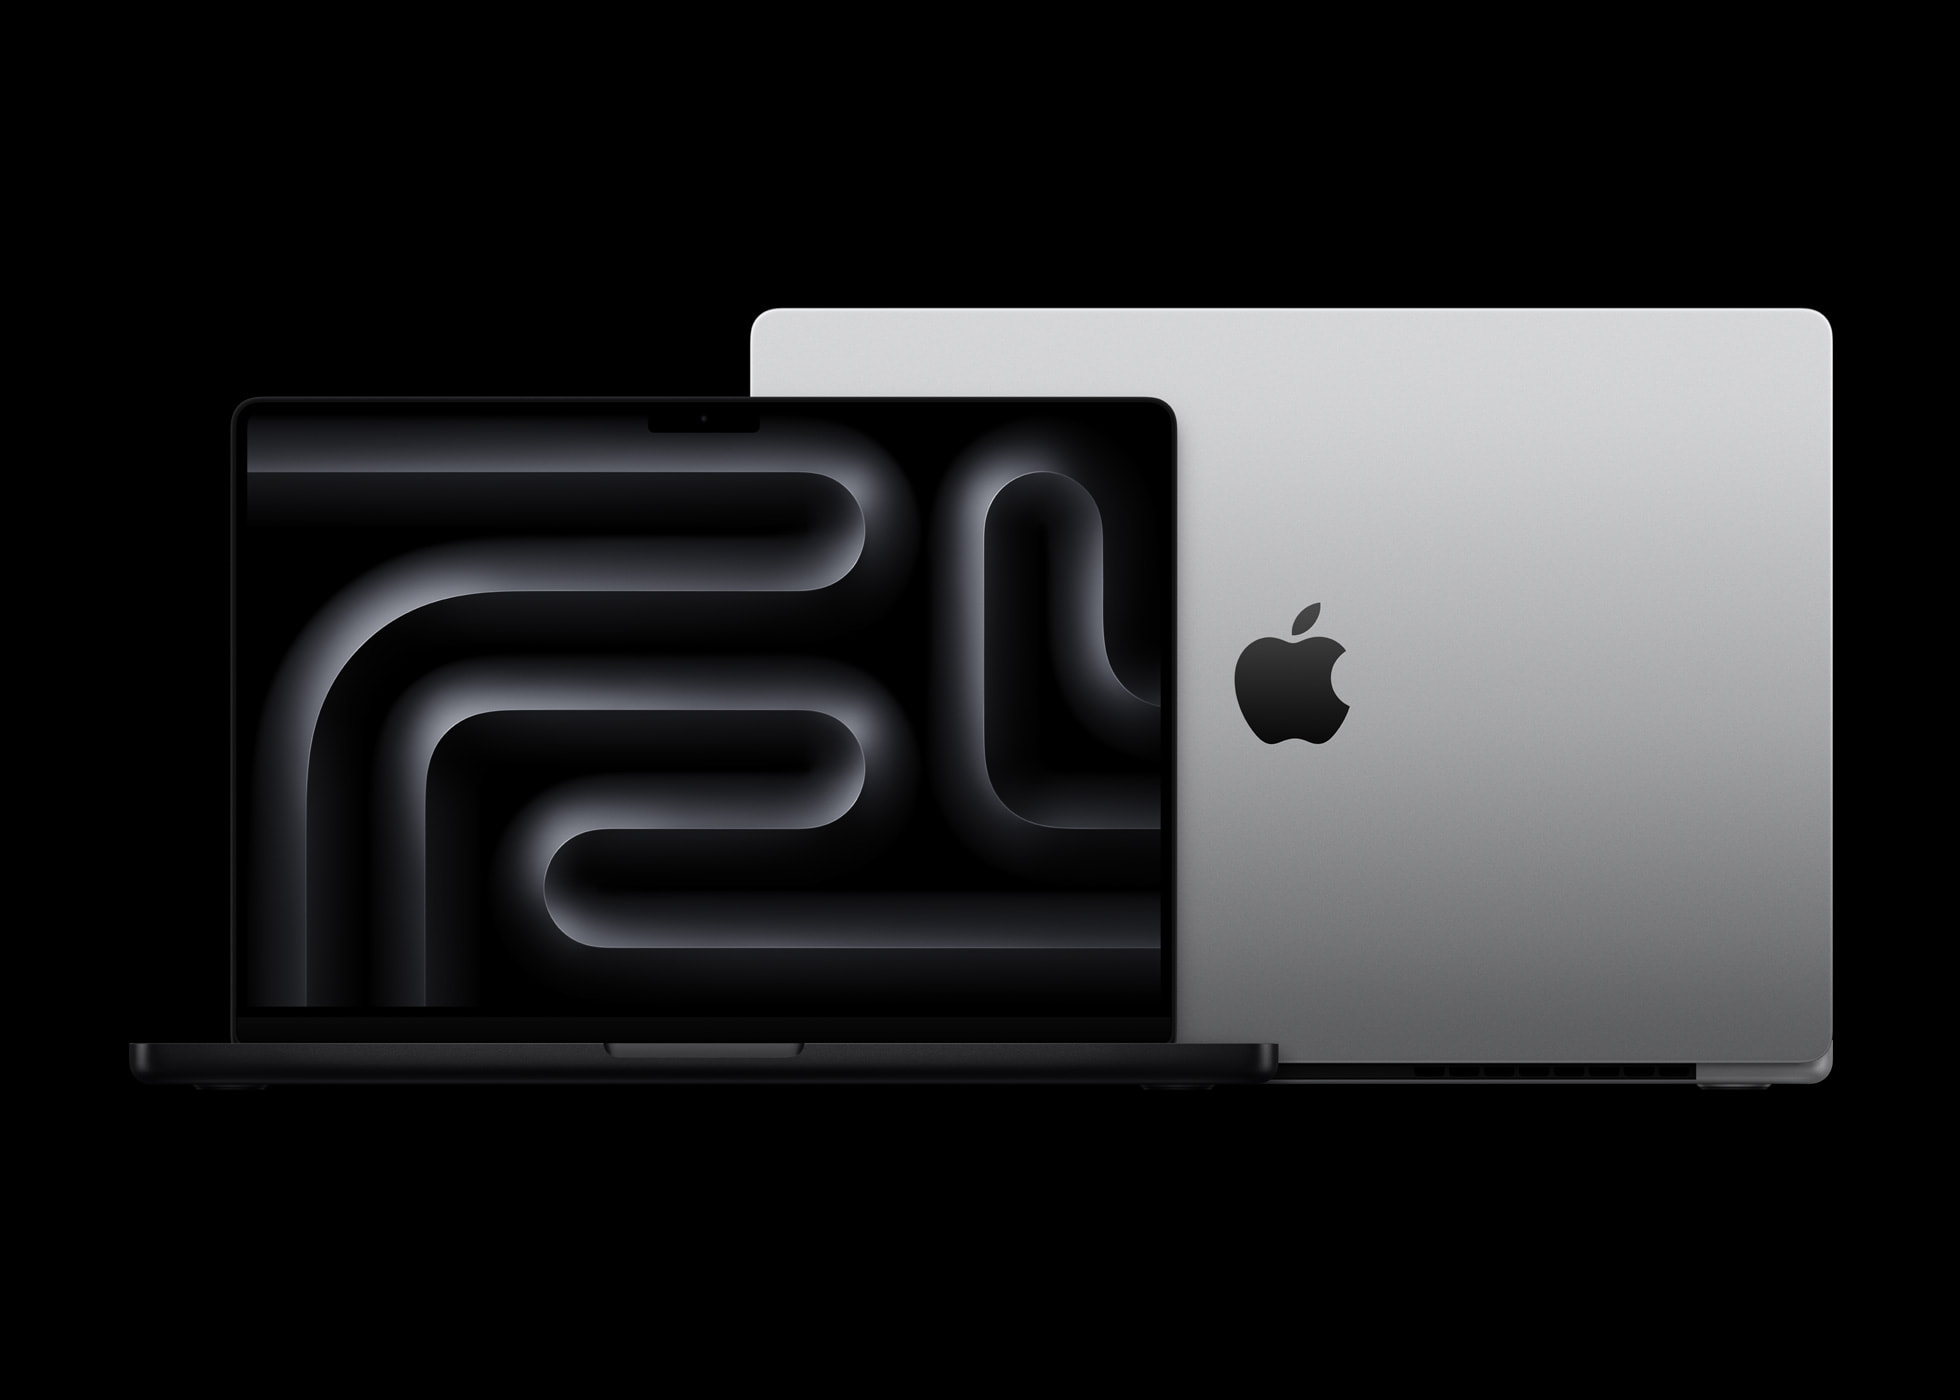
MacBook Pro
Latest 14 or 16-inch MacBook Pro provided to all PhD students and postdocs upon joining during the periods.
Claude AI
A claude team plan for scientists, with standard seats provided free for all students and staff.
NVIDIA Jetson Orin
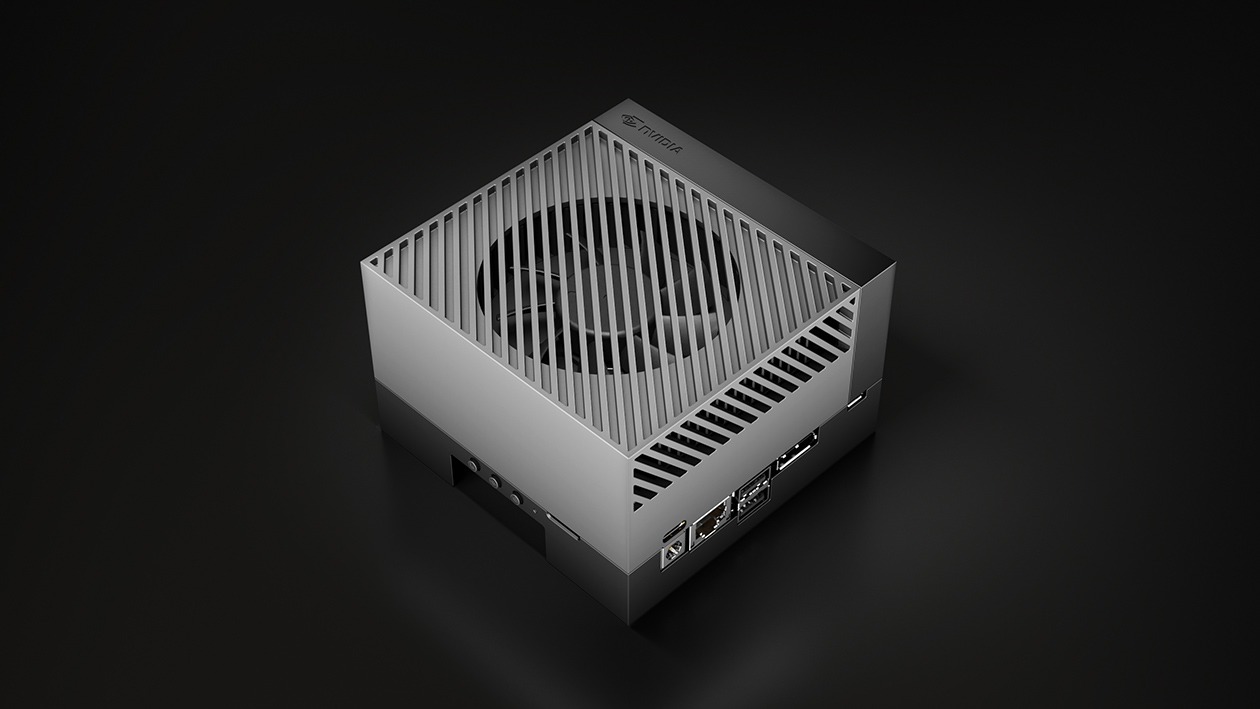
Three Jetson AGX Orin developer units dedicated to onboard robotics perception, sensor fusion, and real-time edge inference. Delivering up to 275 TOPS of AI compute for autonomous navigation and embodied AI experiments.
NVIDIA Jetson Thor
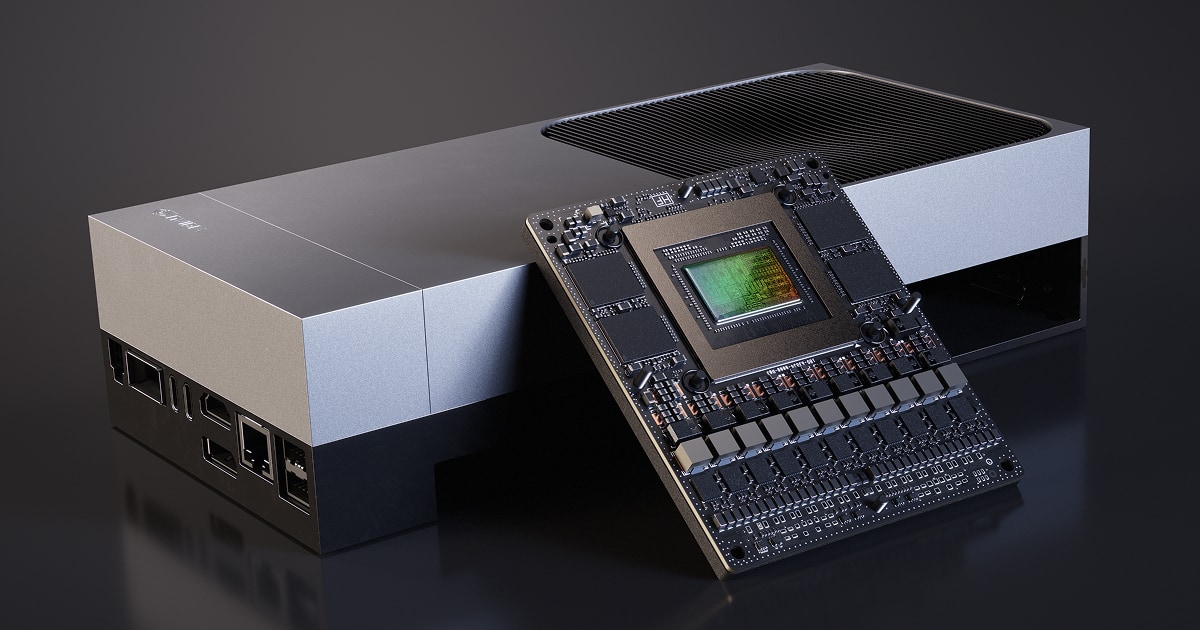
Five next-generation Jetson Thor platforms powering physical AI and humanoid robotics workloads. Delivering over 2,000 TFLOPS of Blackwell-architecture AI compute for real-time multimodal generative reasoning and complex robot control.
M3 Massive Cluster
Monash's institutional HPC cluster, formerly MASSIVE, run by Monash eResearch. Slurm-scheduled CPU and GPU partitions — A100 and H100 nodes among them — sit behind a Lustre parallel filesystem on an RDMA-over-Converged-Ethernet fabric. This is where the multi-day training and large-scale batch jobs go once they outgrow a workstation.